
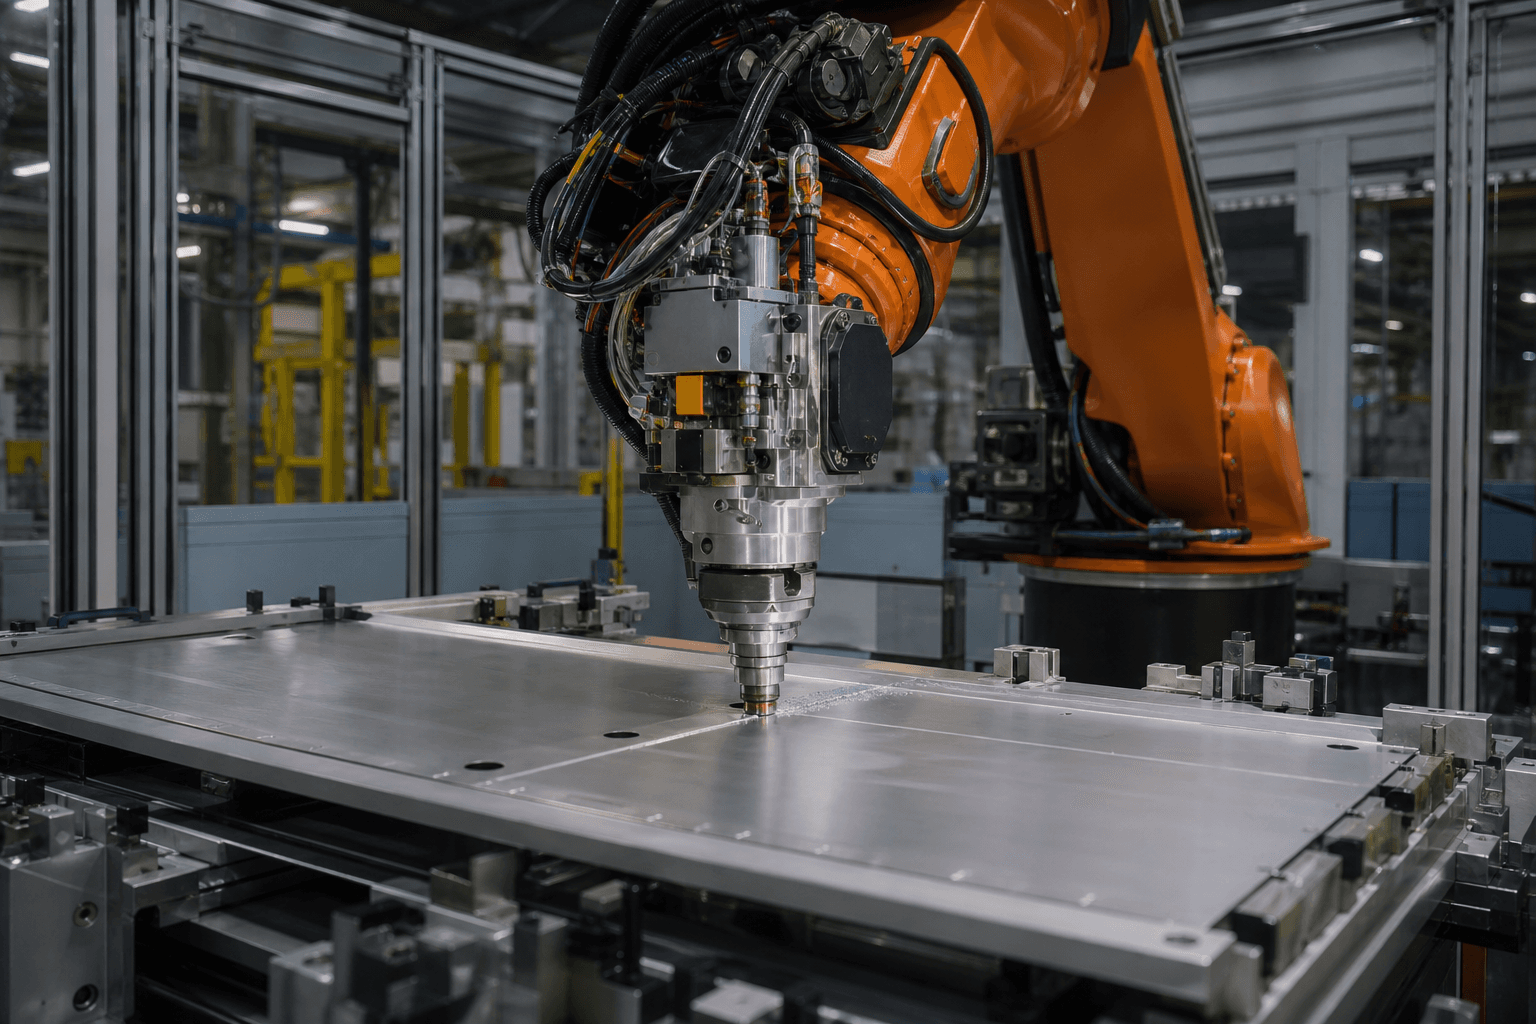
Friction stir welding(FSW)은 종래의 melt pool 없이 접합한다: rotating tool이 plunge하고 traverse하며 plasticized seam을 forge한다. Robot과 gantry는 path를 재현 가능하게 만든다. Worn pin, soft fixture, 또는 oxide와 oil이 남은 aluminum prep는 용서하지 않는다. Adaptive arc welding은 filler가 있는 seam tracking을 소유한다. Laser EV cell은 keyhole monitoring을 소유한다. 이 brief는 robotic FSW를 process cell로 소유한다: force, RPM, travel, tool genealogy.
Takt 이야기 전에 cell이 제어해야 하는 것
- Tool pin/shoulder life — weld meter를 log; dull tool은 wormhole을 발명한다.
- Downforce / forge control — TCP path 미학만이 아니다.
- Fixturing stiffness — deflection은 “robot tuning”처럼 보이지만 아니다.
- Joint prep와 gap — FSW는 mystery gap과 contamination을 싫어한다.
- NDT sampling — lot을 멈출 수 있는 phased array/UT plan.
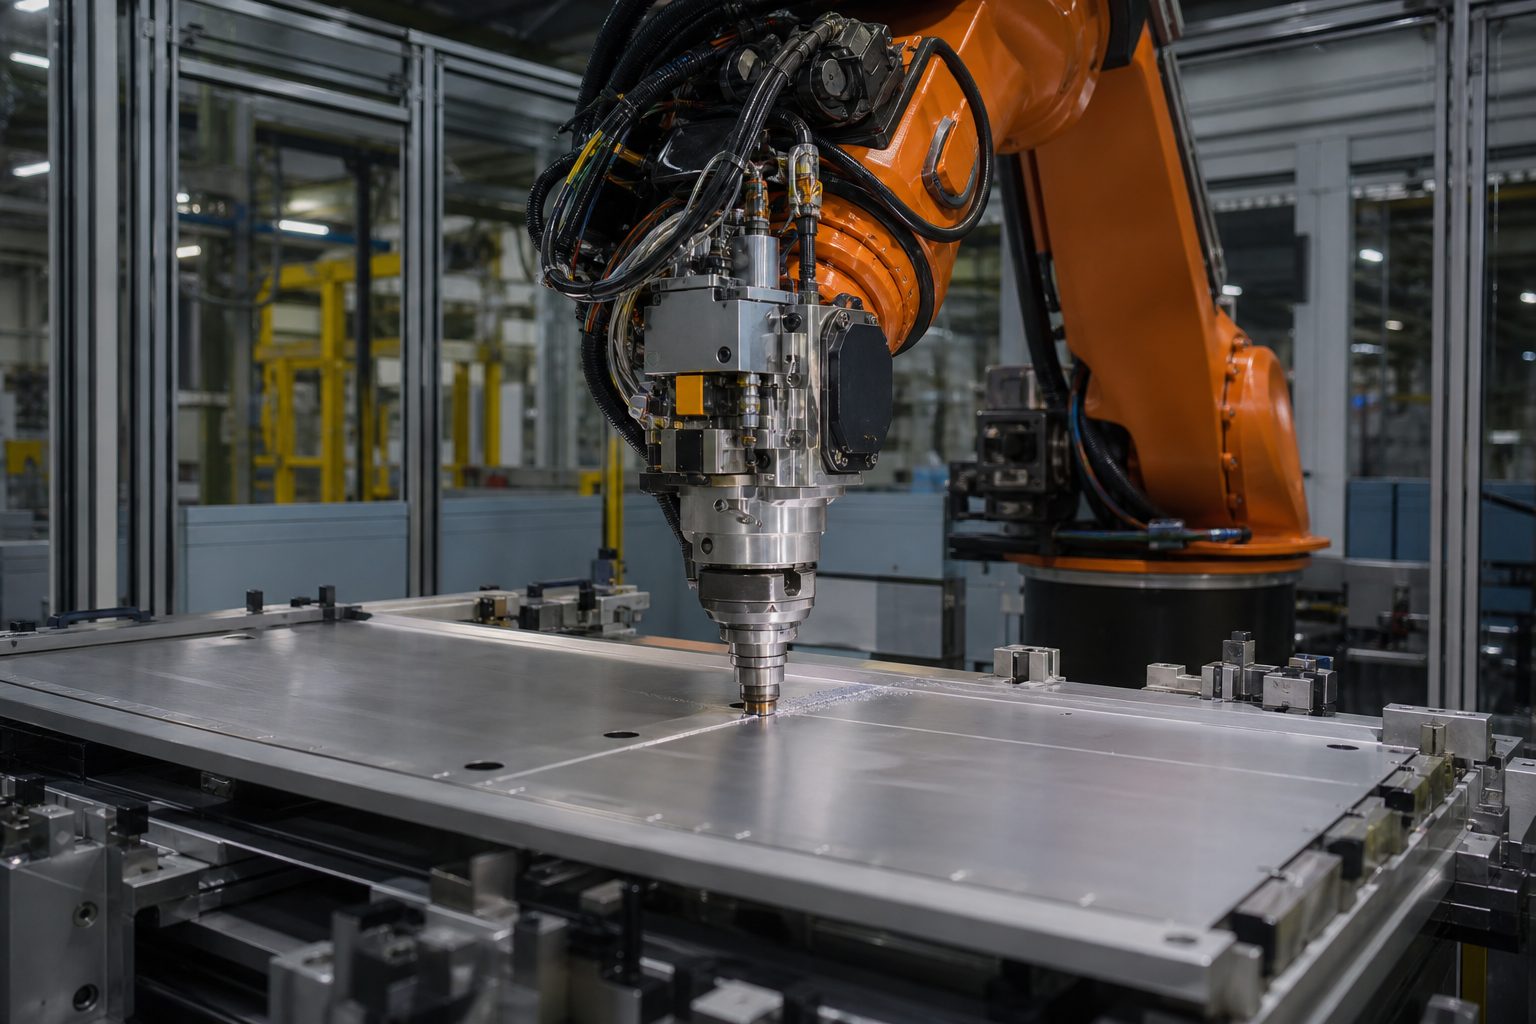
매끄러운 TCP plot은 sound nugget이 아니다.
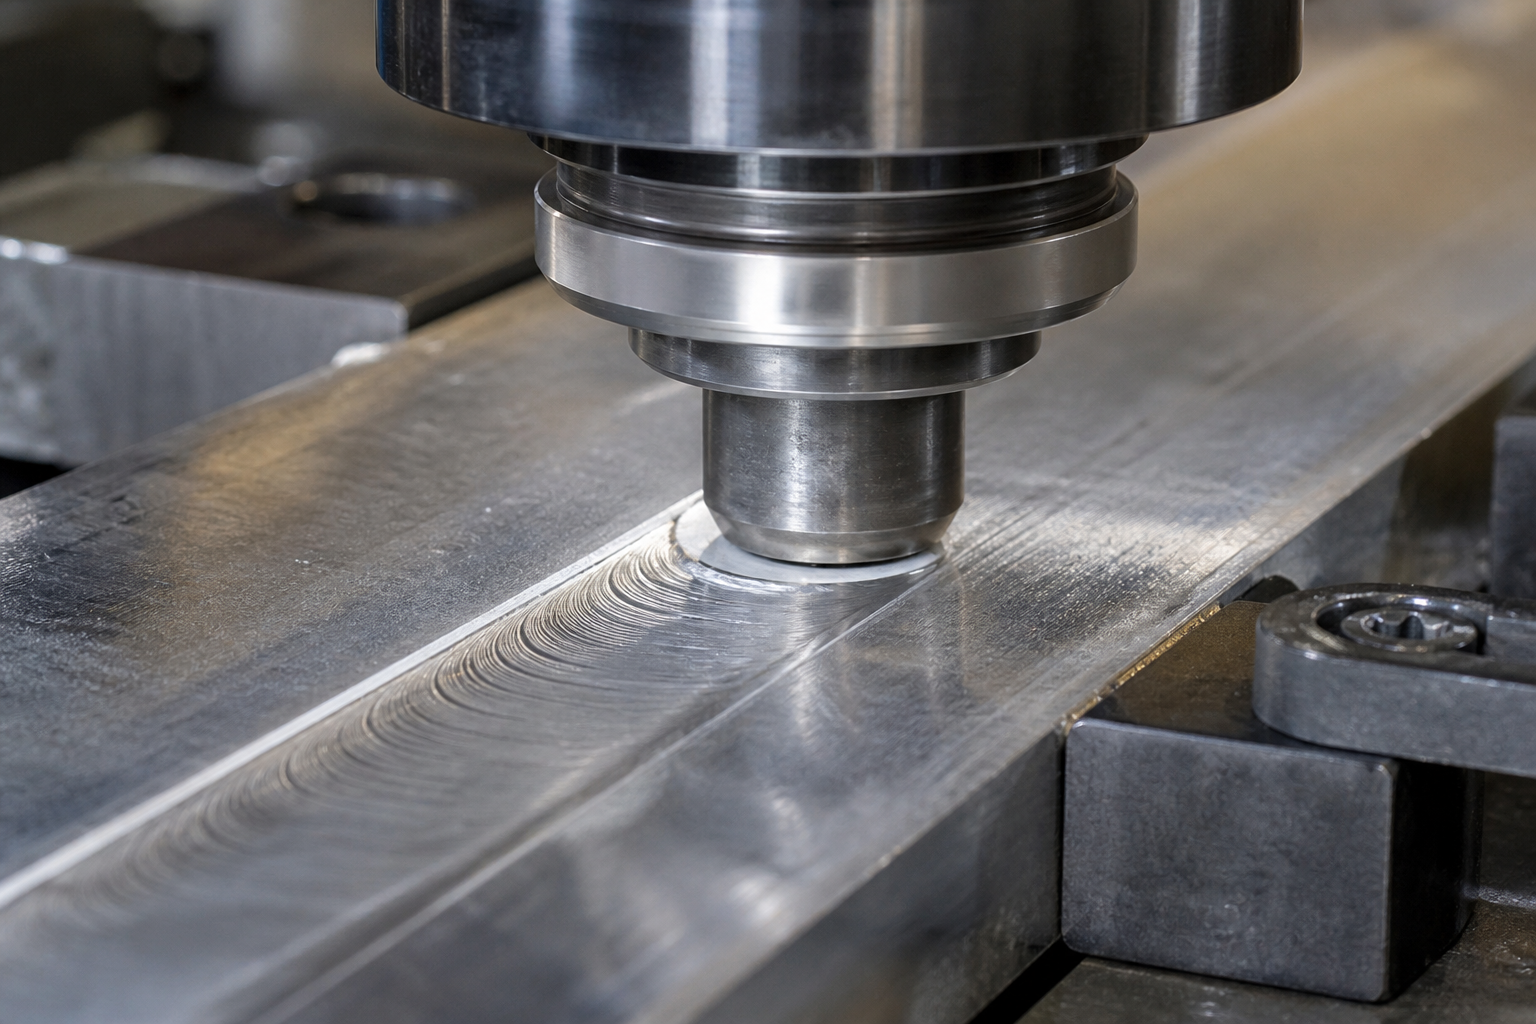
Pin meter는 consumable process parameter다.
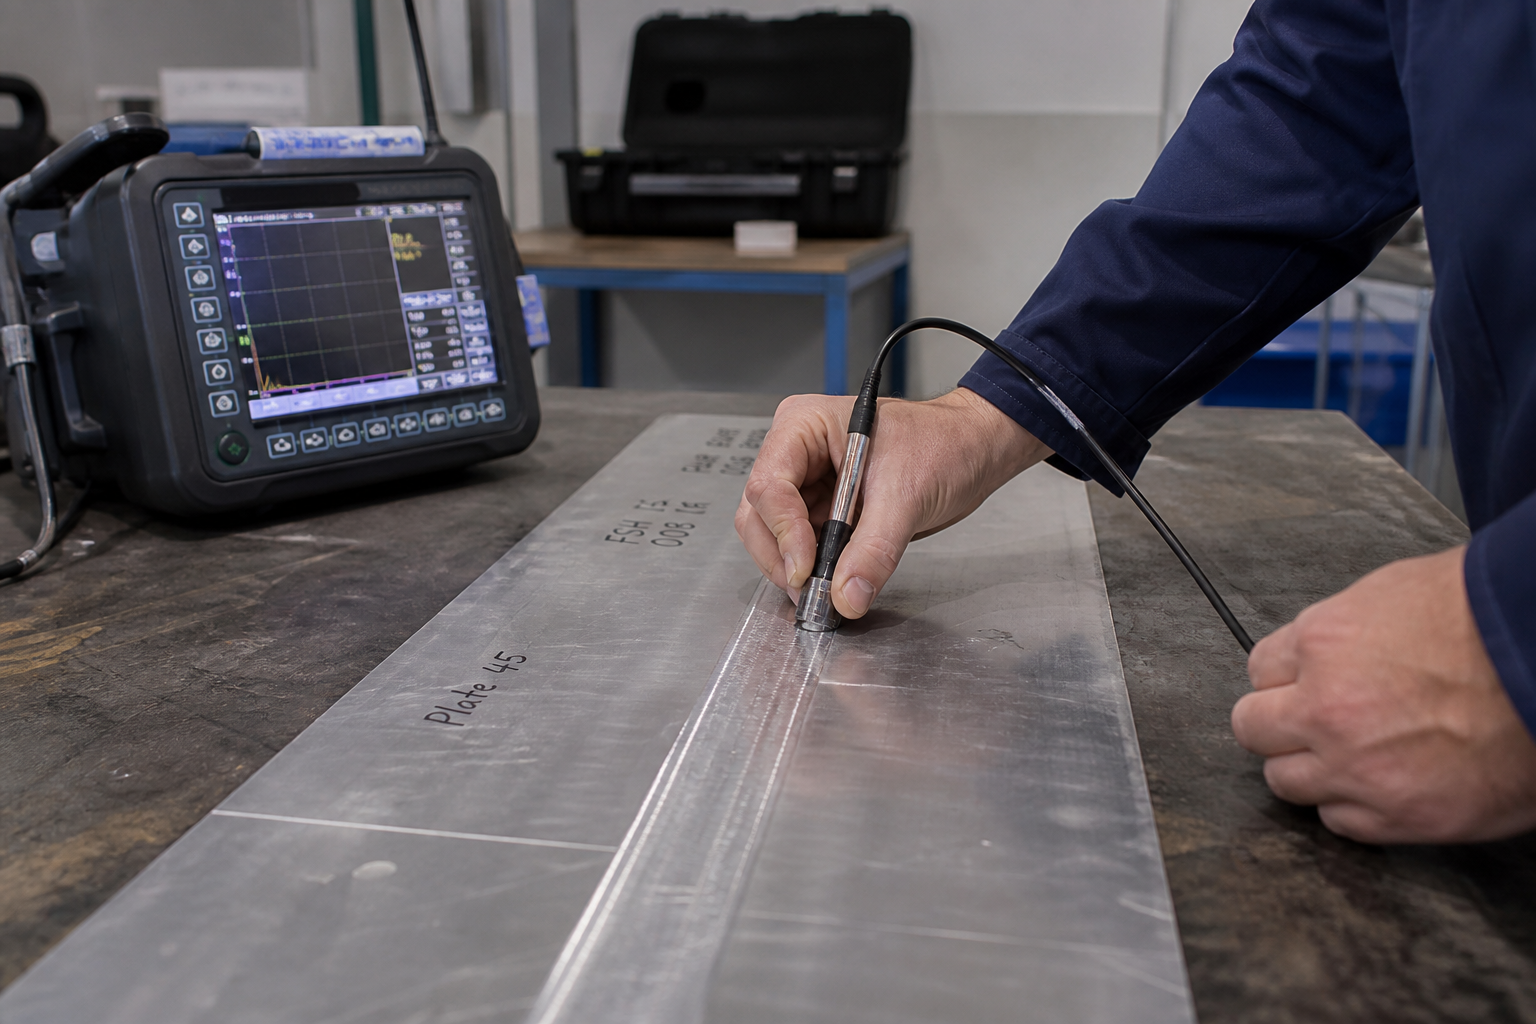
Inspection이 lot을 잡을 수 없다면 path repeatability는 vanity다.
Short rules
- RPM, travel, forge, tool ID를 robot program과 하나의 MoC set으로 freeze하라.
- Pin은 “아직 괜찮아 보인다”가 아니라 meter count로 폐기하라.
- Fixture 변경을 path edit과 동등한 process change로 취급하라.
Adjacent fences
Adaptive AI welding은 arc seam을 소유한다. Laser weld monitoring은 EV tab/bus join을 소유한다. Robotic NDT는 scan path를 소유한다. 이 페이지는 solid-state joining robotics로서의 FSW를 소유한다. Heavy-payload arm을 사고 tool wear가 acceptance test에 한 번도 없었음을 발견하지 말라.