
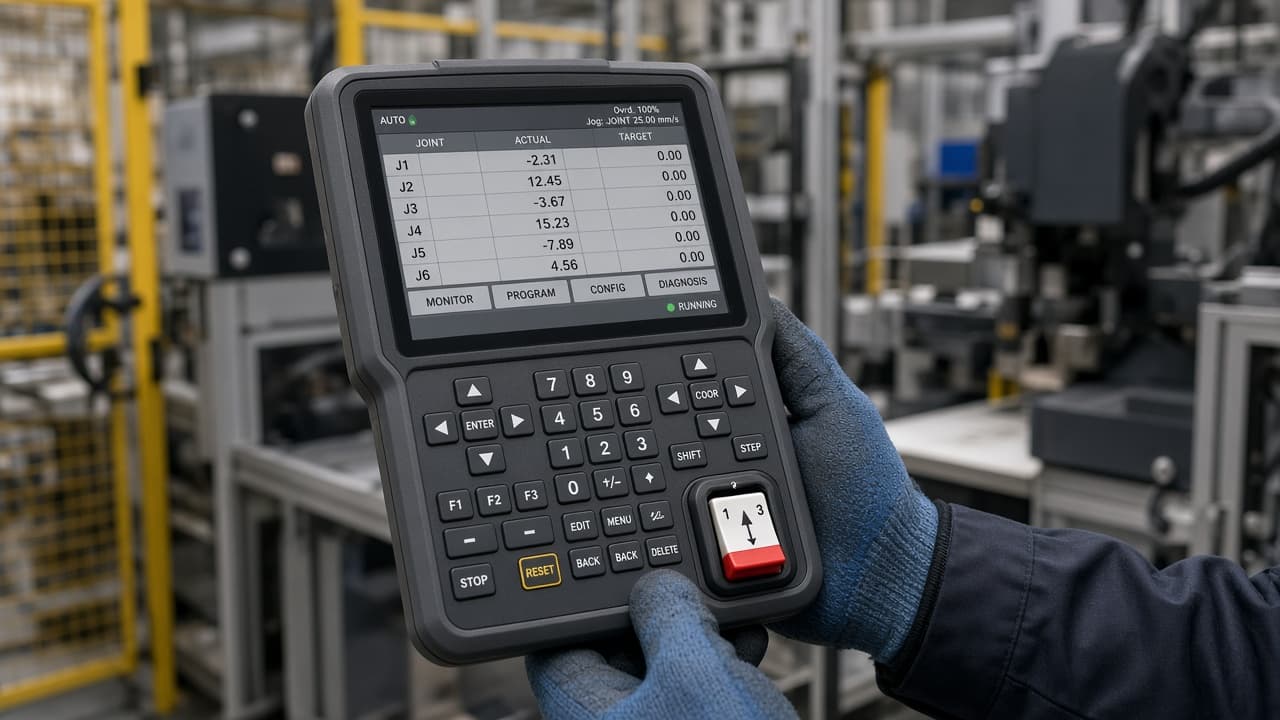
Teach mode is supposed to be the slow, attended way to move a robot. The enable device (deadman)—often a three-position switch on the pendant—is the hardware promise that motion continues only while the operator deliberately holds the middle position. Release or squeeze-through to the third position cuts motion. When that switch is stuck, bypassed, or ignored, the label “teach” on the HMI is decoration.
Safety-scanner muting validation and cobot ISO force-limiting are different safeguarding stories. Robot program backup is software. This note is teach-pendant enable-device integrity.
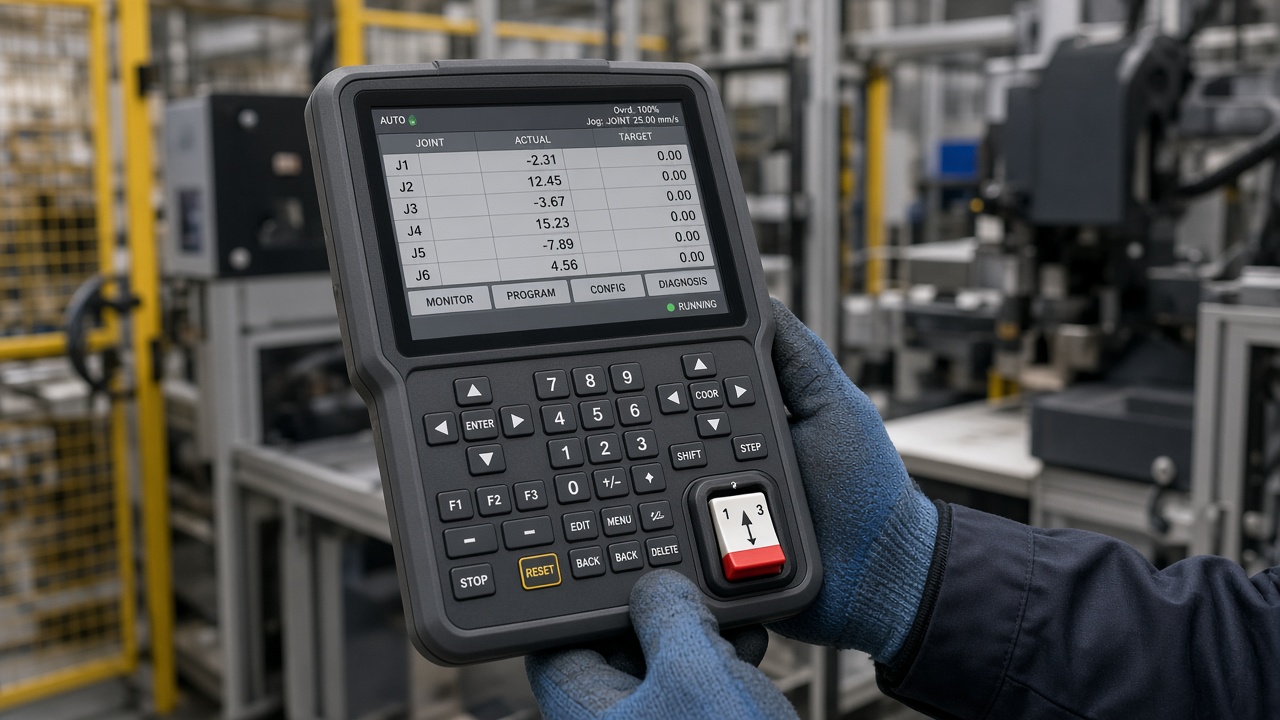
Failures are mundane: contacts welded from abuse, springs tired, cables pinched in the pendant spiral, or a temporary jumper left after a service call. Operators who tape the enable “so we can see the path with both hands” invent the same outcome. A pendant that runs with enable released fails the most basic teach-mode test.
What a shift check should prove
Verify enable off stops motion in teach. Verify middle position allows reduced-speed motion per the cell design. Verify third position (if present) also stops. Log pendant serial and cable condition after any drop. After board or pendant replacement, repeat the enable proof before anyone stands inside the fences.
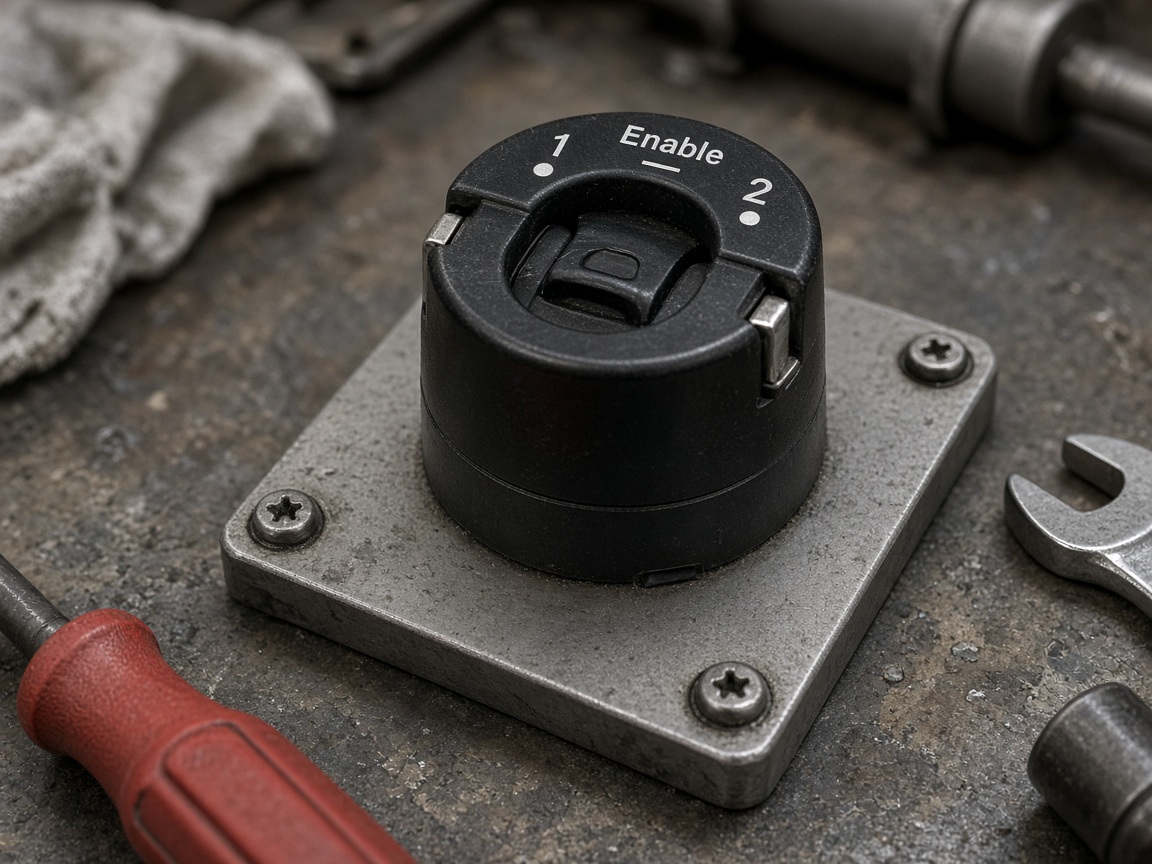
Do not troubleshoot path points with a taped deadman. Fix the switch, replace the pendant, clear the bypass. Teach mode without a working enable device is not productivity—it is an incident waiting for a shift report.